Hi, I'm Lukáš Rustler
Robotics
researcher.
Exploring how robots can perceive, interact with, and safely work alongside people.
A little about me
Research with
a human touch.
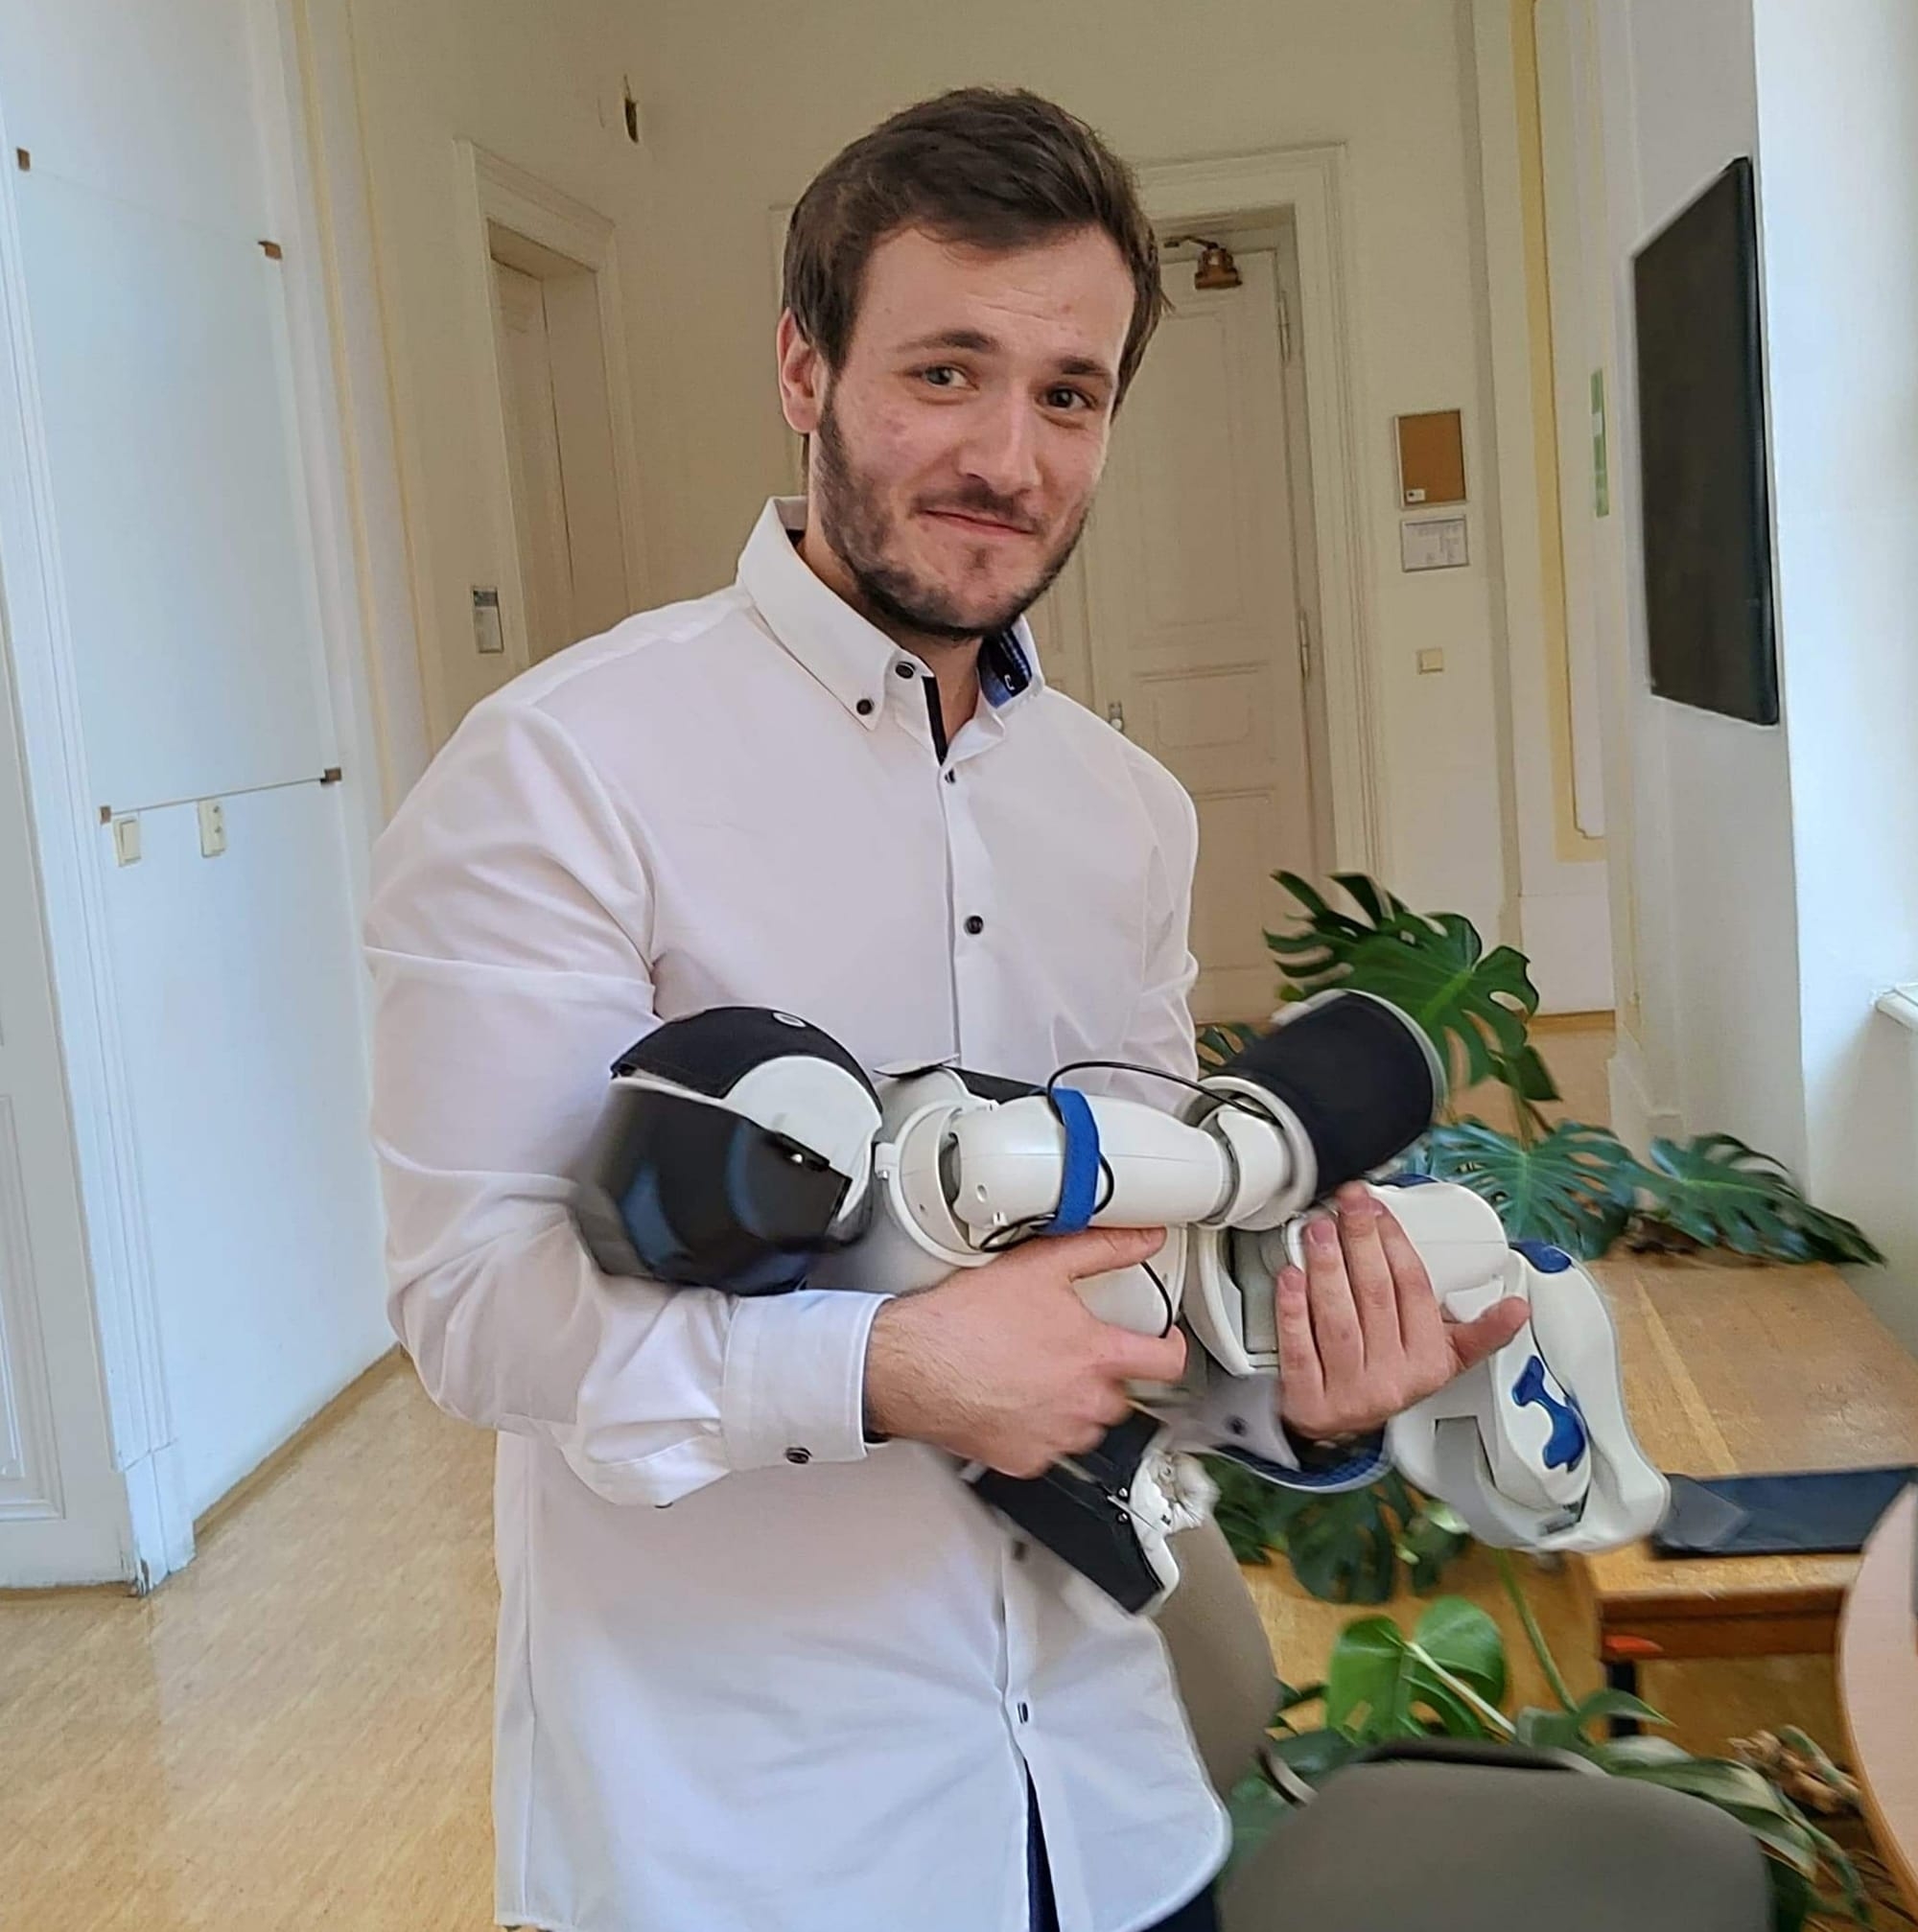
I am a researcher at the Department of Cybernetics, Czech Technical University in Prague, where I recently defended my Ph.D. thesis. My research focuses on active multimodal perception for robotic grasping and manipulation, safe human-robot interaction, and multimodal calibration.
My research has been published at leading robotics conferences, including ICRA, IROS, and Humanoids, and in journals such as IEEE Robotics and Automation Letters and Science Robotics. I have also served as a reviewer for Humanoids, ICRA, and IROS, as well as robotics journals.
Active multimodal perceptionHuman-robot interactionMultimodal calibration
Selected work
Research
Robot in a crib: How a playing robot helps us understand sensorimotor contingency learning
No Need to Look! Locating and Grasping Objects by a Robot Arm Covered with Sensitive Skin
Learning with pyCub: A Simulation and Exercise Framework for Humanoid Robotics
Updates
Latest news
- 15.-18.9.2026 Our paper Simulating Infant First-Person Sensorimotor Experience via Motion Retargeting from Babies to Humanoids was published in the ICDL 2026 proceedings.
- 26.8.2026 Our paper Robot in a Crib: How a Playing Robot Helps Us Understand Sensorimotor Contingency Learning was published in Science Robotics.
- 29.7.2026 Our paper Adaptive Collision Sensitivity for Efficient and Safe Human-Robot Collaboration was published in Advanced Intelligent Systems.
- 1.-5.6.2026 I presented our paper No Need to Look! Locating and Grasping Objects by a Robot Arm Covered with Sensitive Skin at ICRA 2026 in Vienna, Austria.
- 15.-17.4.2026 I presented our paper Learning with pyCub: A Simulation and Exercise Framework for Humanoid Robotics at RiE 2026 in Wolfenbüttel, Germany.
- 22.11.2024 Our paper Adaptive Electronic Skin Sensitivity for Safe Human-Robot Interaction was published in the Humanoids 2024 proceedings.
- 14.10.2024 Our paper Interactive Learning of Physical Object Properties Through Robot Manipulation and Database of Object Measurements was published in the IROS 2024 proceedings.
- 16.4.2025 Our paper Empirical Comparison of Four Stereoscopic Depth Sensing Cameras for Robotics Applications got accepted to IEEE Access!
- 5.3.2025 Check our new preprint! Adaptive Collision Sensitivity for Efficient and Safe Human-Robot Collaboration
- 22.- 24.11.2024 I attended the 2024 IEEE-RAS International Conference on Humanoid Robots in Nancy, France. And presented our paper Adaptive Electronic Skin Sensitivity for Safe Human-Robot Interaction.
- 30.6.2024 Our paper Interactive Learning of Physical Object Properties Through Robot Manipulation and Database of Object Measurements got accepted to IROS 2024, Abu Dhabi, UAE.
- 1.-5.10.2023 I attended IROS 2023 in Detroit, USA and presented our paper Efficient Visuo-Haptic Object Shape Completion for Robot Manipulation.
- 21.6.2023 Our paper Efficient Visuo-Haptic Object Shape Completion for Robot Manipulation got accepted to IROS 2023!
- 29.5.-2.6.2023 I attended ICRA 2023 in London, UK.
- 12.9.-21.12.2022 I had the possibility to visit the Personal Robotics Lab at Imperial College London, UK!
- 23.-27.5.2022 I attended ICRA 2022 in Philadelphia, USA and presented our paper Active Visuo-Haptic Object Shape Completion.
- 20.4.2022 Our paper Effect of active and passive protective soft skins on collision forces in human–robot collaboration got accepted to Robotics and Computer-Integrated Manufacturing (RCIM)!
- 1.2.2022 I started my Ph.D. student journey.
- 31.1.2022 Our paper Active Visuo-Haptic Object Shape Completion got accepted to RA-L and ICRA 2022!
Let's talk
Get in touch.
Have a question or an idea related to robotics? Feel free to reach out.
lukas.rustler@fel.cvut.cz ↗Prague, Czech Republic